CoRL 2026 Workshop
Description
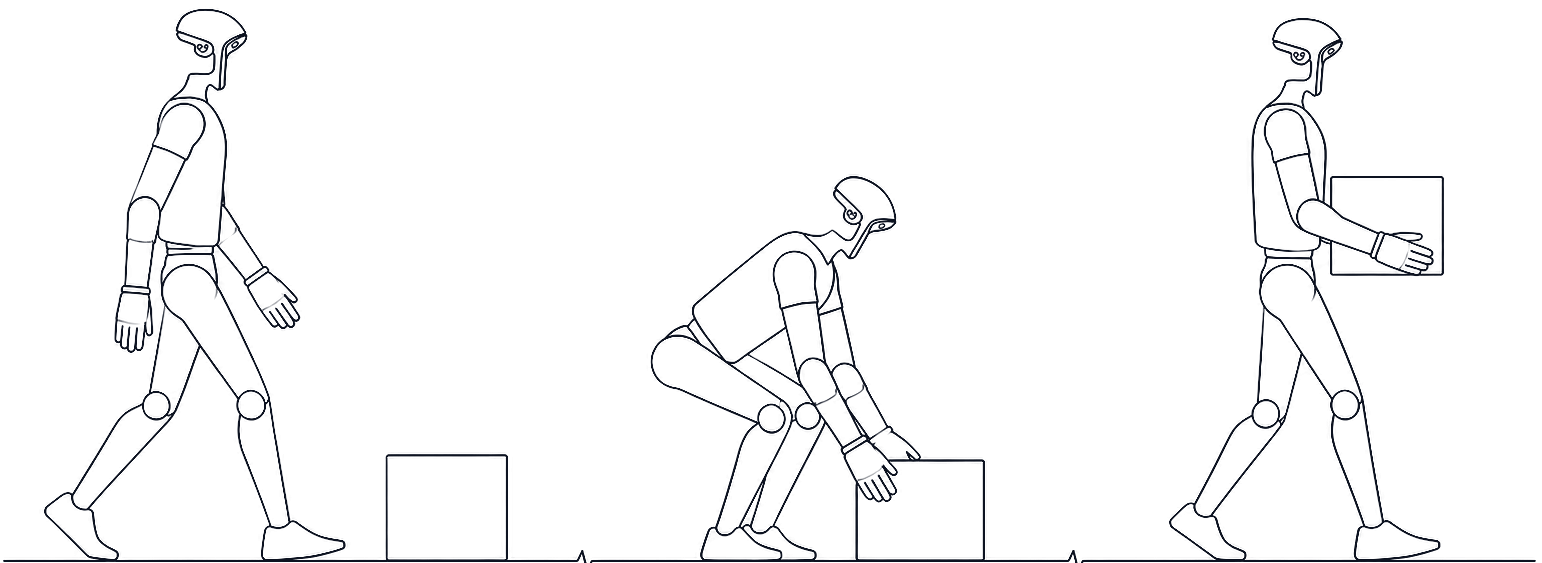
A half-day workshop focused on how robots decide, sense, and control contact while moving through the world, spanning prehensile and non-prehensile skills. This workshop brings together researchers in legged locomotion, mobile manipulation, non-prehensile manipulation, whole-body control, contact-aware planning, onboard perception, and sim-to-real transfer to identify shared challenges and promising research directions.
Event location
Let your network know you`re going
Share this event to start conversations, invite colleagues, and connect before it begins.
Meet the speakers
Alan Fern
Theme:Oregon State University - Robot learning, planning, reinforcement learning, and decision making under uncertainty.
Tao Pang
Theme:Robotics and AI Institute - Contact-rich manipulation, planning, control, and robust physical interaction.
Pulkit Agrawal
Theme:MIT - Robot learning, legged mobility, manipulation, and sim-to-real transfer.
Emo Todorov
Theme:Roboti and University of Washington - Optimal control, physics simulation, contact dynamics, and robot movement.
Related events

Oct 14 - Advances in AI at SDSU

Special 10x Your Job Search with Claude + n8n and Apify - Automate EVERYTHING

Englewood Mastering Claude Code Workflow Essentials
The AI Tasting Room (with The AI Collective Fayetteville)

Build with AI DC
Philly Builds AI Founder Series: On Building, Exiting, and Building Again from 3x Founder Jake Stein of Common Paper
SF Tech Week Lunchtime w/ Rootly AI 🍂🌮
Startup Showcase
Tutor Intelligence: Startup Trek
Secrets of AI-Pilled Organizations
Informationbanker Fintech & AI networking walk