
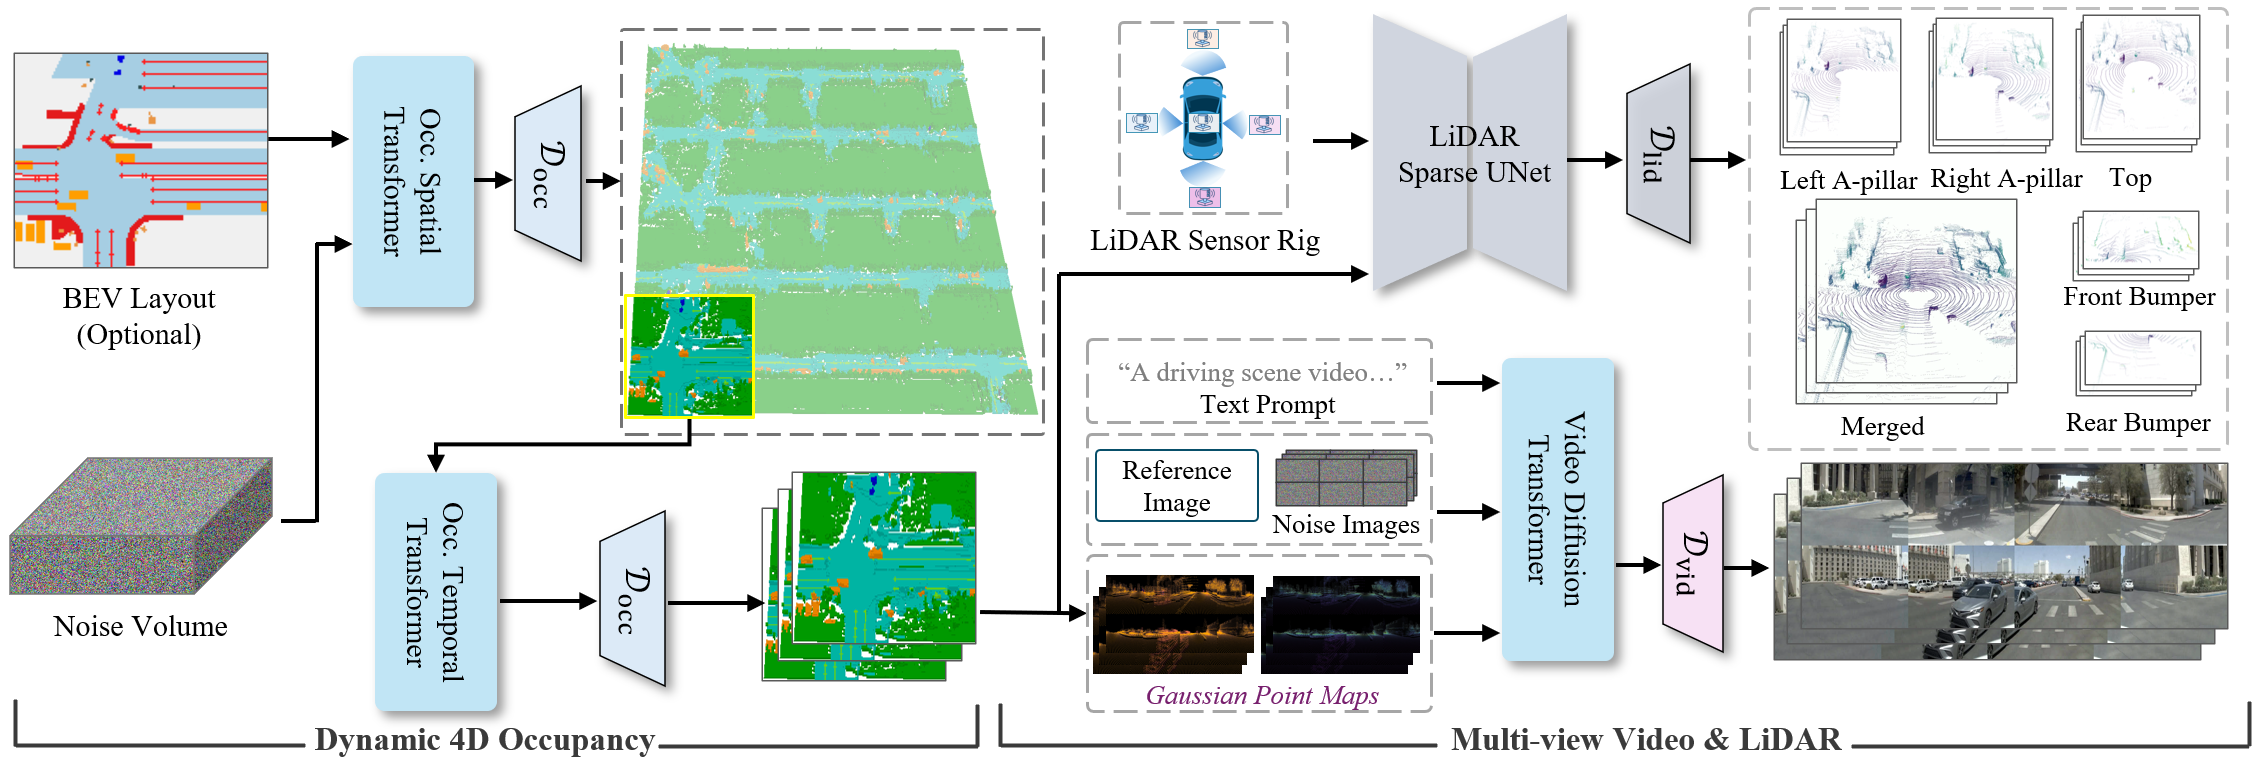
Grounded 4D Multimodal World Models for Autonomous Driving Decision Making
LearnNetwork
Description
A problem-driven workshop on 4D occupancy, multi-view video, LiDAR, and scenario generation that are useful for planning, control, safety validation, and real autonomous systems.
Event location
Let your network know you`re going
Share this event to start conversations, invite colleagues, and connect before it begins.
Meet the speakers
Hao Zhao
Theme:Assistant Professor, Tsinghua University
Hongyang Li
Theme:Assistant Professor, The University of Hong Kong
Long Chen
Theme:Senior Research Director & Principal Scientist, Xiaomi
Wenhao Ding
Theme:Senior Research Scientist, Autonomous Vehicle Group, NVIDIA Research
Related events
The AI Tasting Room (with The AI Collective Fayetteville)

AIBuild with AI
Build with AI DC
Philly Builds AI Founder Series: On Building, Exiting, and Building Again from 3x Founder Jake Stein of Common Paper
4
SF Tech Week Lunchtime w/ Rootly AI 🍂🌮
10
creator lounge party • AGI x YY x 21st x Blue Neck
15
Startup Showcase
4
Tutor Intelligence: Startup Trek
10
Secrets of AI-Pilled Organizations
75
Informationbanker Fintech & AI networking walk
5
SemiAnalysis x vCluster Presents: The Assembly
NYC Frontier Hackathon: Build your Autonomous Code Factory
STEM Spark! Summit 2026
29
Artificial Intelligence Platform
Pricing on website
Get tickets